Your shopping cart is empty!
 English
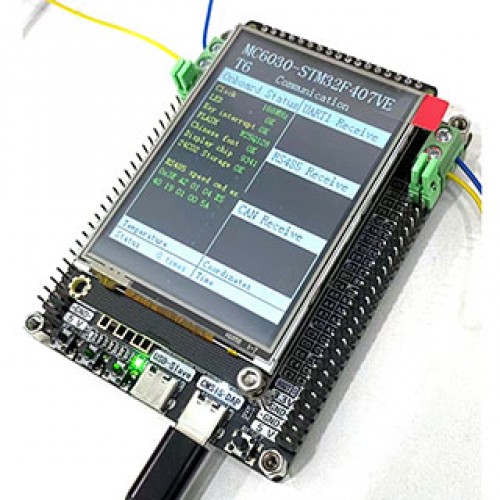
MC6030 v2 Motor controller for step, gimbal, and servo motors with RS485, CAN, SPI, I2C, UART, PWM
Product Code: 25860302
Availability: 10000
Availability: 10000
Price: $136.50
Ex Tax: $136.50
Ex Tax: $136.50
3 or more $133.80
5 or more $132.60
5 or more $132.60
Qty:
- OR -
Add to Wish List
Add to Compare
Add to Compare
25860302 MC6030 v2 Motor controller for step, gimbal, and servo motors, with RS485, CAN, SPI, I2C, UART, PWM
It can support all RMD serial motors drivers.
Application
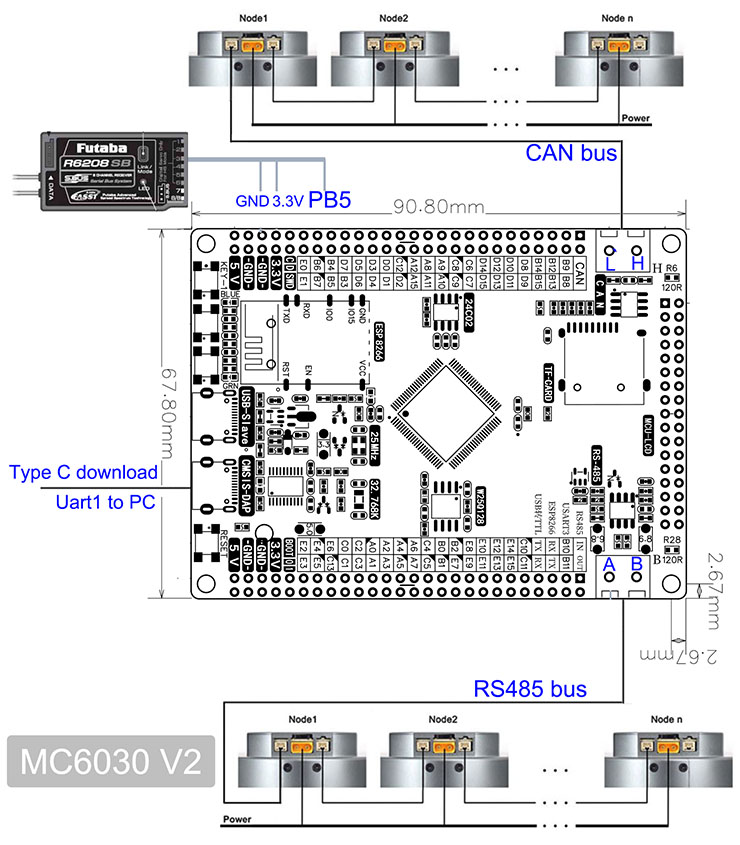
Run RS485 command Sample:
1.On PC send 0x3E A2 01 04 E5 40 19 01 00 5A on USB cable. The testing board receive this command,
and transfer it to RS485 to run the motor on speed mode.
2. Write this command in vTask_100ms() or other similar branches.
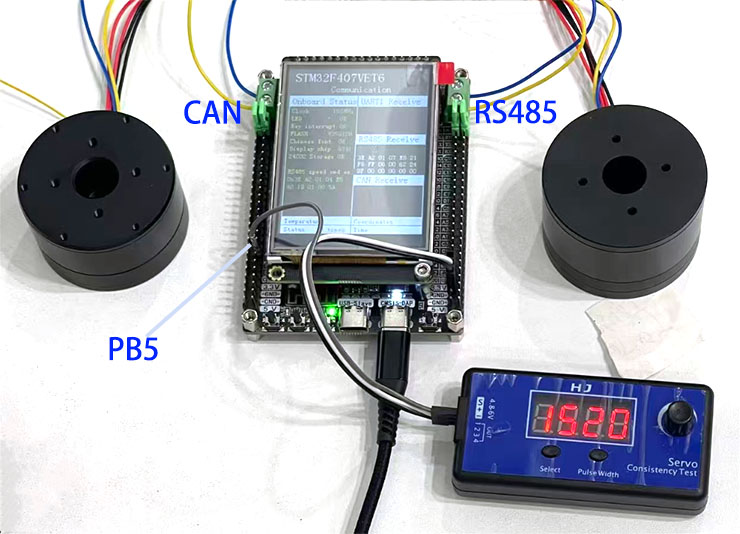
Run motor with RS485 and CAN with controller from receiver PWM signal sample:
1. Connect the receiver to channel 3 and GND 3.3V and PB5
2. The throttle in the middle is 0 speed. The throttle below middle is negative
speed. The throttle above middle is positive speed. The motor RS485 or CAN
Specifications
Input voltage to MC6030 V2: 5V
Input voltage to motor: 10V-24V or 48V according to motor
CPU: STM32F407VET6
CAN: 1x
RS485: 1x
UART: 5x
PWM signal input: PB5 or others
PWM out: PINS out
ADC in: PINS out
DAC out: PINS out
Touch screen: 2.8"
Size: 90.8x67.8x25mm
Firmware: Keil C Program
Weight: 90g
Copyright © 2003-2017 by SMC Powers Ltd. All Rights Reserved. Email: shop@smc-powers.com Skype:smc-power